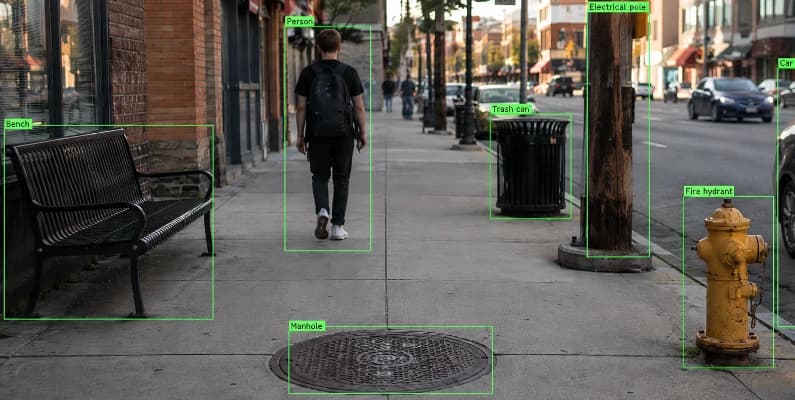
Real-Time Obstacle Detection Dataset
The Real-Time Obstacle Detection Dataset (ROD) is a 24,326-image, 40,195-box, 25-class benchmark for pedestrian obstacle detection. It reconciles 29 public collections onto one class index alongside original street-level capture in Toronto and Tehran, labelled through a SAM 3 workflow with human verification. It has passed 83,000 downloads on Hugging Face and 3,800 on Kaggle.
What I did
- Trained and benchmarked all six nano-scale detectors, YOLOv8n through YOLO26n, under one identical protocol. All six executed notebooks are published as references in the paper.
- Ran field capture and annotation across several of the 13 collection campaigns. Fire hydrant supplies 255 of 255 released boxes for its class, and Bench, after failing the 0.90 admission gate at 0.769 precision, grew from 260 to 774 instances (+197%) through re-photography.
Key finding
I established the paper's central result: recall and mAP rankings disagree, so choosing a detector on aggregate mAP does not give you the one that misses the fewest obstacles. Recall is the metric that matters when a miss is an obstacle the user walks into.
Best results across the six detectors
- 0.889 recall
- 0.925 precision
- 0.882 mAP@0.50
- 0.750 mAP@0.50:0.95
- 1.98M parameters
- 79.7 FPS
Stack & Tools
Links
Other Projects
Augova
The AI automation company I co-founded in August 2026 for small and mid-sized businesses: voice agents, document intelligence, process automation, and custom AI.
Prosecuto
Built at NVIDIA Spark Hack Toronto on GB10 hardware. Owned the local-inference path — on-device llama-server and vLLM NVFP4 instead of a hosted API.
Undercut
Live used-car deal finder that flags mathematically underpriced GTA listings. Built the visualization layer and led the migration to a modular architecture.
SyncAgent
Multi-agent orchestrator that runs Claude Code, Gemini CLI, and Codex CLI on one task, coordinated through markdown files on disk. Python, zero dependencies.
Custom Quadcopter Build
End-to-end embedded build — PCB design in Altium, ArduPilot firmware, DJI flight controller integration, and full PID tuning.
ATF Robotics Cup
National championship-winning autonomous robot against a 5,000+ participant field. Lead software and systems engineer across firmware, PCBs, and competition strategy.
FIRA RoboWorldCup
2nd place nationally and a World Finals qualification. Technical operations manager, troubleshooting firmware live under competition conditions.